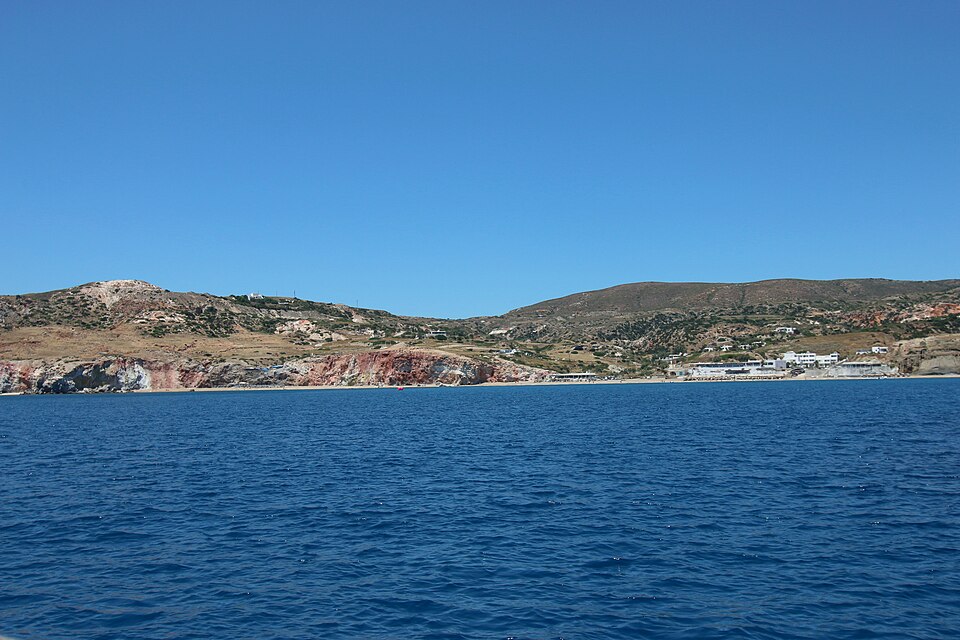
Bubbles make striking underwater footage, but a striking image does not measure how a seep behaves over time. MBARI’s October fieldwork around Milos, Greece, combines ways of seeing the seafloor with ways of recording its activity. An actual deployment log helps distinguish that research process from a finished scientific result.
What the field team has reported
The October 20 field log from Paleochori describes MOLA launches from a boat or shore, autonomous missions, sensor monitoring, data processing and recovery. It is evidence of work underway. It does not announce a completed regional survey, a newly discovered hazard to swimmers or a tested product available for recreational divers.
The official expedition overview lists October 15–25, 2026 fieldwork with the National and Kapodistrian University of Athens. Alongside the MOLA mapping vehicle, the project plans distributed acoustic sensing, hydrophones and a stereo Bubble Cam to study hydrothermal seepage. These provide different measurements that researchers can interpret together.
Map the setting, then consider the activity
A seafloor map helps locate features in relation to one another. A time series asks a different question: how does an observation vary while a sensor remains in place? Neither automatically replaces the other. Knowing where a feature is does not tell you everything about how it behaves across the day.
For readers used to action-camera footage, this is a useful way to read an expedition update. Look for the measurement the instrument actually produces. Then look for how researchers connect it with other measurements. A camera, an acoustic record and a reconstructed surface can support complementary interpretations without becoming identical evidence.
A research platform with a particular role
MBARI’s MOLA platform page describes a modified Boxfish submersible equipped with custom sensors and software. It identifies cameras and sonar used for navigation and mapping, including AI-based algorithms associated with sonar processing. This does not mean every autonomous movement is an AI inference, or that the complete research package is an off-the-shelf recreational accessory.
When assessing a robotics headline, separate three stages: what the platform is designed to do, what the current field log confirms it did, and what analysis has established afterward. The Milos log supports the middle stage. The expedition’s aims should remain aims until results are reported.
Our underwater technology evidence checklist applies this distinction to equipment claims. Here it helps readers follow real field validation without turning an engineering update into a purchasing recommendation or a reason to approach an active vent.
Dates and scope: field log October 20; expedition scheduled October 15–25, 2026. Undated expedition and platform pages checked October 25. No new operational limit, recreational access guidance, scientific discovery or TRIMIX testing result is claimed.
Join the discussion
Share a question or a useful experience about this article. Every comment is reviewed before it appears.